Pseudo-satellite platforms course
About our
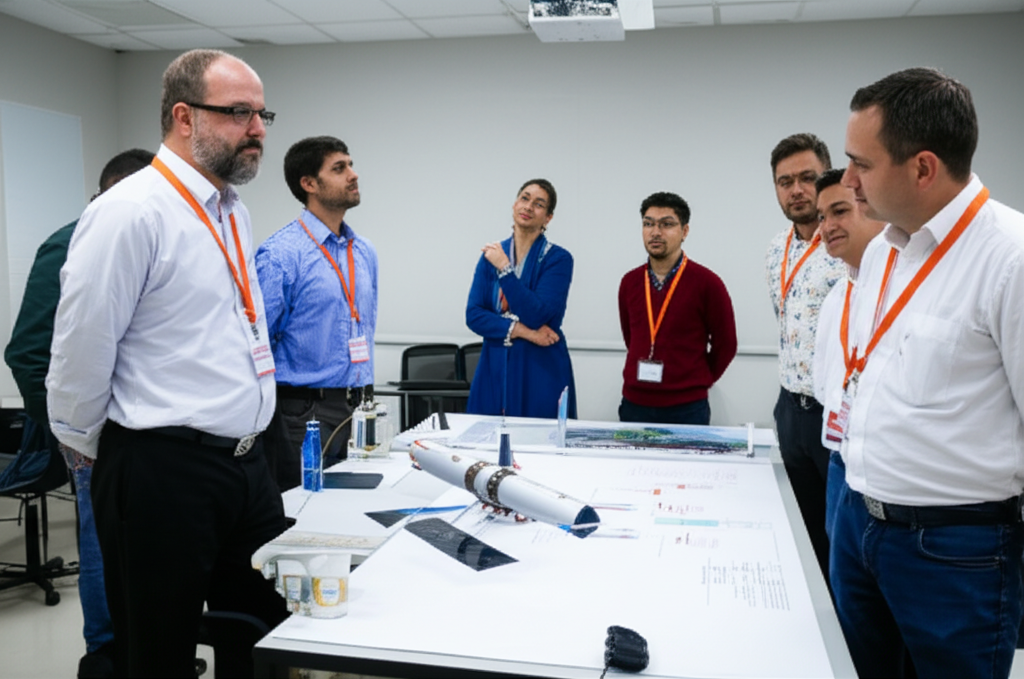
The Pseudo-Satellite Platforms Course explores the design and operation of stratospheric flight systems, combining robotics, aerodynamics, and long-distance communications. It focuses on the development of high-altitude platforms, using solar-powered drones and other technologies for environmental observation and analysis. The course covers systems engineering, telecommunications, and remote sensing, as well as data management and software integration, which are crucial for the implementation of these platforms. The course provides hands-on experience in mission planning, data analysis, and flight simulation, preparing participants for roles in atmospheric research, environmental monitoring, and the development of high-performance telecommunications technologies. It focuses on compliance with flight regulations and on optimizing the energy efficiency of systems, with an emphasis on sustainability and social impact.
Pseudo-satellite platforms course
- Format: Hybrid
- Duration: 3 months
- Hours: 300 H
- Language: English / Spanish
- Registration date: 23-10-2026
- Start date: 12-12-2026
- Available places: 2
620 $
Competencies and results
What you will learn
1. Design and Operation of Pseudo-Satellite Platforms: A Comprehensive Course
- Understand the fundamental principles of HAPS (Highly Airborne Parasatellite Platform) design.
- Explore the different HAPS configurations and architectures, including aerostats and aircraft.
- Analyze the mission requirements and applications of HAPS in areas such as telecommunications, Earth observation, and surveillance.
- Study the propulsion and flight control systems of HAPS, including engines, propellers, and steering systems.
- Learn about power and energy management systems, including solar panels, batteries, and storage systems.
- Analyze the communication and data link systems used in HAPS, including antennas, radios, and communication protocols.
- Design and simulate the aerodynamic performance of HAPS using simulation software.
- Evaluate the stability and control of HAPS under different flight conditions.
- Understand the structural design aspects of HAPS, including materials, strength, and durability.
- Analyze the launch, recovery, and operational systems of HAPS.
- Study the regulatory and safety aspects related to the operation of HAPS.
- Explore future trends and developments in HAPS technology.
2. Aerodynamic and Structural Analysis of High Altitude Platforms
2. Aerodynamic and Structural Analysis of High-Altitude Platforms
- In-depth study of crucial aeroelastic phenomena, including flap-lag-torsion coupling analysis, whirl flutter, and structural fatigue assessment.
- Master advanced aeronautical structural design, encompassing the design and analysis of composite laminates, the study of structural joints, and the simulation of bonded joints using Finite Element (FE) techniques.
- Apply cutting-edge methodologies to ensure structural integrity, including the implementation of damage tolerance strategies and the use of Non-Destructive Testing (NDT) techniques such as Ultrasonic Testing (UT), Radiography (RT), and Thermography.
3. Comprehensive user-oriented design and validation (from modeling to manufacturing)
You will learn to integrate the entire product development process, from initial model conception to final validation, applying user-centered methodologies. You will develop skills in parametric design, ergonomics, simulation, sustainable materials, 3D visualization, and manufacturing management, ensuring efficient, safe solutions that meet current industry standards.
4. Implementation of Control Systems for Pseudo-Satellite Platforms
- Design and analysis of robust and adaptive control systems.
- Dynamic modeling of high-altitude satellite platforms (HAPS).
- Implementation of control algorithms for stability and navigation.
- Integration of sensors and actuators in control systems.
- Analysis of the stability and performance of control systems.
- Simulation and validation of control systems in complex environments.
- Optimization of control systems for energy efficiency and performance.
- Implementation of control systems for energy and payload management.
- Application of predictive control techniques and machine learning.
- Development of software and hardware for HAPS control systems.
5. Evaluation and Adjustment of Flight Trajectories on Pseudo-Satellite Platforms
- Master the fundamental principles of flight dynamics applied to pseudo-satellite platforms.
- Understand trajectory evaluation methodologies, including modeling and simulation.
- Apply trajectory tuning techniques to optimize performance and efficiency.
- Study the factors that influence the stability and control of these platforms.
- Analyze and mitigate the risks associated with flight operations.
- Use specialized software for trajectory analysis and design.
- Interpret flight data and perform accurate diagnostics.
- Develop real-time decision-making skills during flight.
- Implement strategies for managing emergencies and critical situations.
- Become familiar with the regulations and standards applicable to pseudo-satellite platforms.
6. Analysis of Propulsion Models and Structures of HAPS Platforms
6. Analysis of Propulsion Models and Structures of HAPS Platforms
Study failure modes in blades and rotors.
Understand aeroelasticity in propulsion systems.
Evaluate structural dynamics and their impact on integrity.
Identify instability mechanisms in rotors.
Analyze flap-lag-torsion couplings, whirl flutter, and fatigue.
Dimension laminates in composites, joints, and bonded joints with FE.
Implement damage tolerance and NDT. (UT/RT/thermography).
Who this program is for:
Pseudo-satellite platforms course
- Graduates in Aerospace Engineering, Mechanical Engineering, Industrial Engineering, Automation Engineering, or related fields.
- Professionals in OEM rotorcraft/eVTOL, MRO, consulting, and technology centers.
- Flight Testing, certification, avionics, control, and dynamics seeking specialization.
- Regulators/authorities and UAM/eVTOL professionals requiring compliance skills.
Recommended requirements: foundation in aerodynamics and control and structures; ES/EN B2+/C1. We offer bridging tracks if you need them.
- Standards-driven curriculum: you will work with CS-27/CS-29, DO-160, DO-178C/DO-254, ARP4754A/ARP4761, ADS-33E-PRF from the first module.
- Accreditable laboratories (EN ISO/IEC 17025) with rotor bench, EMC/Lightning pre-compliance, HIL/SIL, vibrations/acoustics.
- Evidence-oriented TFM: safety case, test plan, compliance dossierand operational limits.
- Mentored by industry: teachers with experience in rotorcraft, tiltrotor, eVTOL/UAM and flight test.
- Flexible modality (hybrid/online), international cohorts and support from SEIUM Career Services.
- Ethics and security: safety-by-design approach, cyber-OT, DIH and compliance as pillars.
1.1 Introduction to HAPS Platforms: Definition and Classification
1.2 HAPS Platform Architecture: Key Components
1.3 Conceptual Design of HAPS Platforms: Factors to Consider
1.4 HAPS Platform Operations: Planning and Deployment
1.5 Design of Control Systems for HAPS Platforms
1.6 Power Systems for HAPS Platforms: Sources and Management
1.7 Structural Design and Materials for HAPS Platforms
1.8 Communication and Data Link in HAPS Platforms
1.9 Regulatory and Normative Considerations for HAPS Platforms
1.10 Case Study: Design and Operation of a Specific HAPS Platform
2.2 Fundamentals of High-Altitude Aerodynamics
3.2 Structural Design for High-Altitude Environments
4.3 Load and Stress Analysis on HAPS Platforms
5.4 Advanced Materials and Their Application in HAPS
6.5 Structural Modeling and Simulation of Platforms
7.6 Aerodynamic Optimization to Maximize Efficiency
8.7 Stability and Aerodynamic Control Analysis
9.8 Impact of Altitude on Aerodynamic Design
20.9 Wing and Control Surface Design for HAPS
22.20 Integrated Structural and Aerodynamic Design Considerations
3.3 Conceptual Design: Key Factors
3.2 Component Selection: Motors, Solar Cells
3.3 Structural Design: Materials and Loads
3.4 Flight Control Systems: Autonomy and Stability
3.5 Communication Systems: Data Link and Remote Control
3.6 Mission Planning: Routes and Operations
3.7 Safety Considerations: Design and Protocols
3.8 Cost and Operation Analysis: Feasibility
3.9 Regulatory Aspects: Regulations and Permits
3.30 Case Studies: Successful Platforms
2.3 Aerodynamic Principles: Lift and Drag
2.2 Aerodynamic Modeling: CFD and Software
2.3 Structural Analysis: Loads and Stresses
2.4 Material Selection: Weight and Strength
2.5 Wing Design: Shape and Efficiency
2.6 Wind Resistance: Effects and Mitigation
2.7 Structural Integrity: Safety Factors
2.8 Wind Tunnel Testing: Validation
2.9 Failure Analysis: Modes and Effects
2.30 Structural Optimization: Lightweight Design
3.3 Introduction to Simulation: Tools and Methodologies
3.2 Environmental Modeling: Atmosphere and Wind
3.3 Flight Simulation: Dynamics and Control
3.4 Performance Optimization: Key Variables
3.5 Systems Simulation: Components and Subsystems
3.6 Design of Experiments: Optimization Techniques
3.7 Monte Carlo Simulation: Uncertainty Analysis
3.8 Model Validation: Comparison with Real Data
3.9 Simulation Software: Selection and Use
3.30 Case Studies: Successful Optimization
4.3 Control Architecture: Sensors and Actuators
4.2 Controller Design: PID and Modern Control
4.3 Attitude Control: Stability and Orientation
4.4 Trajectory Control: Navigation and Tracking
4.5 Navigation Systems: GPS and Inertial Navigation Systems
4.6 Algorithm Design: Control Software
4.7 Control Testing: Hardware-in-the-Loop
4.8 Control Robustness: Noise and Disturbances
4.9 Control Implementation: Real Platform
4.30 Stability Analysis: Criteria and Techniques
5.3 Flight Dynamics: Equations and Models
5.2 Trajectory Planning: Algorithms and Optimization
5.3 GPS Navigation: Accuracy and Integrity
5.4 Autonomous Flight Control: Systems and Functions
5.5 Trajectory Tracking: Control and Adjustments
5.6 Trajectory Management: Mission Planning
5.7 Error Analysis Trajectory Metrics
5.8 Obstacle Avoidance Systems: Sensors
5.9 Regulatory Requirements: Airspace
5.30 Case Studies: Flight Trajectories
6.3 Electric Propulsion: Motors and Efficiency
6.2 Solar Cells: Design and Performance
6.3 Lightweight Structures: Composite Materials
6.4 Solar Cell Design: Integration
6.5 Drag Analysis: Airflow and Heat
6.6 Fuselage Design: Wind Resistance
6.7 Electric Motors: Selection and Performance
6.8 Power Systems: Storage and Distribution
6.9 Structural Testing: Loads and Failures
6.30 Propeller Design: Efficiency and Noise
7.3 Communication Technologies: Data Link
7.2 Sensors: Types and Applications
7.3 Observation Applications Earth: Data and Analysis
7.4 Telecommunications Applications: Coverage
7.5 Surveillance Applications: Security and Monitoring
7.6 Systems Design: Component Integration
7.7 Deployment and Operation: Logistics and Maintenance
7.8 Regulatory Framework: Norms and Standards
7.9 Future Trends: Innovation and Development
7.30 Case Studies: Real-World Applications
8.3 Mathematical Modeling: Equations
8.2 Subsystem Modeling: Components
8.3 Multidisciplinary Simulation: Interaction
8.4 Model Design: Software and Tools
8.5 Systems Modeling: Information Flow
8.6 Model Validation: Simulation and Data
8.7 Sensitivity Analysis: Variables
8.8 Model-Based Optimization: Design
8.9 Modeling Software: Tools
8.30 Case Studies: Successful Modeling
4.4 Introduction to Control Systems for Pseudo-Satellite Platforms
4.2 Control System Design: Principles and Methodologies
4.3 Sensors and Actuators: Key Components in Platform Control
4.4 Modeling and Simulation of Control Systems for HAPS
4.5 Control Algorithms: Advanced Techniques
4.6 Attitude and Position Control on Pseudo-Satellite Platforms
4.7 Trajectory and Navigation Control
4.8 Control System Integration: Hardware and Software
4.9 Testing and Validation of Control Systems
4.40 Case Studies: Real-World Applications of Control Systems on Pseudo-Satellite Platforms
5.5 HAPS Trajectory Planning and Design
5.5 Atmospheric Modeling and its Effects on Flight
5.3 Flight Dynamics and Stability of HAPS Platforms
5.4 Navigation and Guidance Systems for HAPS
5.5 Trajectory Control and Tracking Algorithms
5.6 Trajectory Optimization for Coverage and Efficiency
5.7 Flight Simulation and Performance Evaluation
5.8 In-Flight Event and Contingency Management
5.9 Real-Time Trajectory Adjustment
5.50 Case Studies: Trajectories in Real-World Environments
6.6 Design of Pseudo-Satellite (PS) Platform Systems
6.2 Design Considerations for Stratospheric Operation
6.3 Material and Component Selection
6.4 Integration of Power and Communication Systems
6.5 Flight Operation Planning and Execution
6.6 Safety Management and Risk Mitigation
6.7 Design for Longevity and Maintainability
6.8 Regulatory and Normative Considerations
6.9 Case Studies of Operational PS Platforms
6.60 Deployment and Recovery of PS Platforms
2.6 Principles of High-Altitude Aerodynamics
2.2 Platform Stability and Control Analysis
2.3 Modeling and Simulation of Platform Structures
2.4 Structural Design for Extreme Loads and Conditions
2.5 Material Selection and Fatigue Analysis
2.6 Finite Element Analysis (FEA) for PS Platforms
2.7 Structural Optimization Techniques
2.8 Risk Assessment and Failure Analysis
2.9 Testing and Validation of Structural Models
2.60 Design of Lightweight and Durable Structures
3.6 Introduction to PS Platform Simulation
3.2 Modeling of Systems and Component(s)
3.3 Flight Simulation and Performance Analysis
3.4 Design Optimization for Different Missions
3.5 Analysis of Design Sensitivity and Robustness
3.6 Simulation Tools and Specialized Software
3.7 Validation and Verification of Simulation Models
3.8 Simulation of Mission Scenarios and Risk Analysis
3.9 Trajectory Optimization and Energy Consumption
3.60 Simulation and Optimization Case Studies
4.6 Fundamentals of Control Systems for PS Platforms
4.2 Design of Attitude and Navigation Control Systems
4.3 Sensors and Actuators for High-Altitude Platforms
4.4 Implementation of Advanced Control Algorithms
4.5 Integration of Control Systems with Other Systems
4.6 Testing and Calibration of Control Systems
4.7 Autonomous Flight Control and GPS-Based Navigation
4.8 Control Systems for Energy Management
4.9 Safety and Redundancy Considerations
4.60 Control System Integration and Simulation
5.6 Fundamentals of Flight Path Evaluation
5.2 Flight Path Generation and Planning
5.3 Path Performance Analysis
5.4 Real-Time Path Correction and Tuning
5.5 Navigation and Positioning Systems
5.6 Meteorological and Atmospheric Considerations
5.7 Airspace Management and Flight Coordination
5.8 Path Optimization for Specific Missions
5.9 Risk Assessment and Error Mitigation
5.60 Path Evaluation and Tuning Case Studies
6.6 Types of Propulsion Systems for HAPS Platforms
6.2 Propulsion System Performance Analysis
6.3 Design and Selection of HAPS Platform Structures
6.4 Materials Composites and their application in HAPS
6.5 Structural and fatigue analysis
6.6 Thermal management and cooling
6.7 Integration of propulsion and structural systems
6.8 Testing and validation of propulsion systems
6.9 Safety and reliability considerations
6.60 Design for maintenance and durability
7.6 Communication technologies for PS platforms
7.2 Remote sensing and Earth observation applications
7.3 Telecommunications and connectivity applications
7.4 Renewable energy technologies for PS platforms
7.5 Payload systems and sensors
7.6 PS platforms as scientific research platforms
7.7 Integration of PS platforms with other technologies
7.8 Market analysis and economic feasibility
7.9 Future trends and industry development
7.60 Case studies of PS platform applications
8.6 Introduction to modeling and simulation of PS platform systems
8.2 Modeling and simulation tools
8.3 Modeling of Subsystems: Power, Communication, Control
8.4 Mission Scenario Simulation and Performance Analysis
8.5 Sensitivity Analysis and Design Optimization
8.6 Modeling of Environmental Interaction
8.7 Simulation of Systems Integration
8.8 Model Validation and Verification
8.9 Real-Time and Hardware-in-the-Loop Simulation
8.60 Modeling and Simulation Case Studies
- Hands-on methodology: test-before-you-trust, design reviews, failure analysis, compliance evidence.
- Software (depending on licenses/partners): MATLAB/Simulink, Python (NumPy/SciPy), OpenVSP, SU2/OpenFOAM, Nastran/Abaqus, AMESim/Modelica, acoustics tools, planning toolchains DO-178C.
- SEIUM Laboratories: scale rotor bench, vibrations/acoustics, EMC/Lightning pre-compliance, HIL/SIL for AFCS, data acquisition with strain gauging.
- Standards and compliance: EN 9100, 17025, ISO 27001, GDPR.
Capstone-type projects
- Autonomous HAPS Platform Design: Integration of aerodynamics, control, and propulsion; simulation and validation.
- HAPS Performance Analysis: Trajectory optimization, model analysis, and simulation.
- HAPS Control System: Implementation and tuning of flight control; testing in a simulated environment.
- HAPS Applications: Research on sensors and applications; data validation on the HAPS platform.
- HAPS Design and Simulation: 3D and aerodynamic modeling; load and structural analysis.
- Control and Stabilization: Implementation of control systems; simulated flight testing.
- Pathway Optimization: Navigation algorithms and flight planning.
- Application Analysis: Scenario planning and data validation.
- HAPS Platform Development: Design, construction, flight testing, aerodynamic and structural analysis, control systems, simulation, and trajectory analysis.
- Propulsion Optimization: Modeling, simulation, and evaluation of propulsion systems for HAPS platforms.
- Payload Analysis: Integration and analysis of payloads, including communications and sensors, for specific applications.
- Validation and Testing: Ground and flight testing to verify the performance and functionality of the HAPS platform.
- HAPS Design and Simulation: 3D modeling, structural analysis, CFD aerodynamics.
- HAPS Control and Navigation: Implementation of control algorithms, GPS navigation.
- HAPS Trajectory Optimization: Route analysis and simulation, performance evaluation.
- HAPS Applications and Technologies: Case studies, sensor integration.
Admissions, fees, and scholarships
- Profile: Background in Computer Engineering, Mathematics, Statistics, or related fields; practical experience in NLP and valued information retrieval systems.
- Documentation: Updated CV, academic transcript, SOP/statement of purpose, project examples or code (optional).
- Process: Application → Technical evaluation of profile and experience → Technical interview → Review of case studies → Final decision → Enrollment.
- Fees:
- Single payment: 10% discount.
- Payment in 3 installments: No fees; 30% upon registration + 2 equal monthly payments of the remaining 35%.
Monthly payment: available with a 7% commission on the total; annual review.
Scholarships: based on academic merit, financial need, and promoting inclusion; agreements with companies in the sector for partial or full scholarships.
See “Calendar & Calls for Applications,” “Scholarships & Grants,” and “Fees & Financing” in the SEIUM mega-menu.
Do you have any questions?
Our team is ready to help you. Contact us, and we will respond as soon as possible.
F. A. Q
Frequently asked questions
Yes, we have international certification
Yes: experimental models, real data, applied simulations, professional environments, real case studies.
It is not mandatory. We offer leveling tracks and tutoring.
Completely. It covers e-propulsion, integration, and emerging regulations (SC-VTOL).
Recommended. There are also internal challenges and consortiums.
Yes. Online/hybrid modality with planned labs and visa support (see “Visa & Residence”).