Autonomous Vehicles in Urban Environments Course
About our
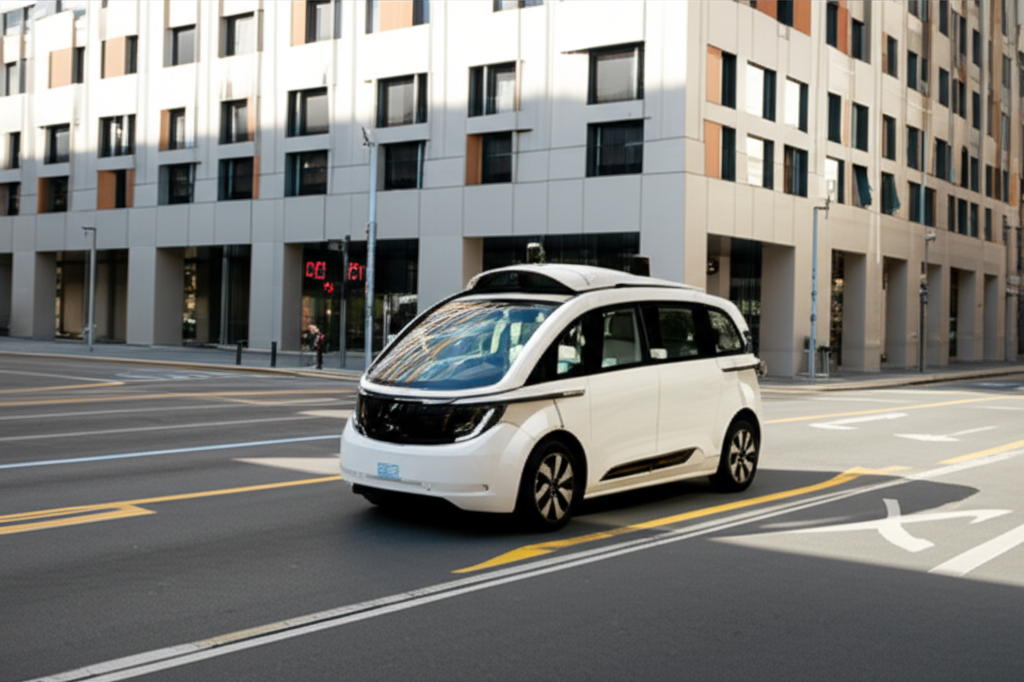
The Autonomous Vehicles in Urban Environments course offers an immersive experience in autonomous driving technology, focusing on the application of perception, route planning, and control algorithms in complex urban scenarios. Topics explored include LiDAR sensors and cameras, machine learning for object detection, and simulation for the development and testing of autonomous systems. The course connects with areas such as artificial intelligence, robotics, and telematics.
Participants acquire practical skills in using vehicle simulation software, analyzing sensor data, and implementing control algorithms. The importance of safety, legislation, and ethical aspects related to autonomous vehicles is addressed. This training prepares professionals for roles in software development, systems engineering, and research in the field of urban autonomous mobility.
Autonomous Vehicles in Urban Environments Course
- Format: Online
- Duration: 3 months
- Hours: 300 H
- Language: English / Spanish
- Registration date: 23-10-2026
- Start date: 12-12-2026
- Available places: 3
799 $
Competencies and results
What you will learn
1. Comprehensive Mastery of Autonomous Urban Vehicles: Design, Navigation and Safety
- Fundamentals of Urban Autonomous Vehicle Design: Explore the key principles that govern the creation of these vehicles, from system architecture to the selection of essential components.
- Mechanical and Structural Design: Learn to design the structure of an autonomous vehicle, including material selection, strength and durability analysis, and the design of suspension and steering systems.
- Navigation and Control Systems: Master autonomous navigation algorithms, including localization, mapping, and route planning, as well as control systems for stability and maneuverability.
- Sensors and Perception: Study the different types of sensors used in autonomous vehicles (cameras, lidar, radar, ultrasound) and how to process data for environmental perception and decision-making.
- Artificial Intelligence and Machine Learning: Understand how AI and machine learning techniques are applied to autonomous driving, including object classification and pedestrian detection.
- Security and Cybersecurity: Learn about the security standards, cybersecurity protocols, and validation tests necessary to ensure the safety of autonomous vehicles and protect them against malicious attacks.
- Legislation and Regulation: Gain an overview of current and future regulations related to autonomous vehicles, including the legal and ethical aspects of autonomous driving.
- Simulation and Testing: Use simulation tools to test and validate the performance of autonomous vehicles, and participate in tests in real-world environments to evaluate their behavior and safety.
and real-time decision-making.
2. In-depth Analysis of Autonomous Urban Vehicles: Control, Simulation and Validation
Here is the requested content:
-
Fundamentals of Autonomous Vehicles: Understanding the pillars of autonomous driving, from sensory perception to decision-making.
- Control Systems Architecture and Design: Exploring control architectures specific to autonomous vehicles, including PID controllers, predictive control, and model-based control.
- Environmental Perception: Analyze sensor-based perception systems such as cameras, lidar, radar, and ultrasound, and how data is fused to create an accurate representation of the environment.
-
Software and hardware design for autonomous vehicles: study the software and hardware architectures used in autonomous vehicles, including embedded systems, high-performance processors, and communication buses.
Autonomous Vehicle Simulation: Learning to use simulation tools to evaluate vehicle performance in complex urban environments, including sensor simulation, environmental modeling, and traffic simulation.
Autonomous Systems Validation and Verification: Mastering methodologies for validating and verifying the safety and performance of autonomous vehicles, including testing in simulated and real-world environments.
Pathway Planning and Decision-Making: Study path planning and decision-making algorithms for safe and efficient navigation in urban environments, including global and local planning.
Legislation and Ethical Considerations: Understand the legal and ethical aspects related to autonomous driving, including liability, safety, and privacy.
Applications of Artificial Intelligence in Autonomous Vehicles: Explore the use of artificial intelligence techniques, such as machine learning and neural networks, to improve perception, control, and decision-making.
Challenges and future trends: analyze current challenges in the development of autonomous vehicles and explore future trends in the industry, including technological evolution, societal impact, and market trends.
3. Comprehensive user-oriented design and validation (from modeling to manufacturing)
You will learn to integrate the entire product development process, from initial model conception to final validation, applying user-centered methodologies. You will develop skills in parametric design, ergonomics, simulation, sustainable materials, 3D visualization, and manufacturing management, ensuring efficient, safe solutions that meet current industry standards.
4. Specialization in Urban Autonomous Vehicles: Perception, Planning and Control
- Fundamentals of perception in urban environments: sensors, image processing, and data fusion.
- Path planning algorithms for autonomous vehicles: route generation, obstacle avoidance, and restriction compliance.
- Control techniques for autonomous vehicles: speed control, steering, and path tracking.
- Navigation and positioning systems: GPS, IMU, and SLAM.
- Software architectures for autonomous vehicles: ROS and other platforms.
- Safety and validation aspects of autonomous systems.
- Regulations and standards applicable to urban autonomous vehicles.
- Simulation and testing in virtual environments.
- Machine learning applied to autonomous driving: object detection, classification, and decision-making.
- Prototype development and experimentation with autonomous vehicles at scale.
5. Expert Exploration in Urban Autonomous Vehicles: Development, Testing and Deployment
- Fundamentals of autonomy in urban environments: sensors, perception, planning, and control.
- Software architectures for autonomous vehicles: ROS, development and simulation platforms.
- Design and development of perception systems: computer vision, LiDAR, radar, and sensor fusion.
- Path planning and navigation: search, mapping, and simultaneous localization (SLAM) algorithms.
- Control of autonomous vehicles: predictive control strategies, robust control, and distributed control.
- Testing and validation of autonomous vehicles: simulations, testing in controlled environments, and real-world deployment.
- Safety and cybersecurity considerations in autonomous vehicles.
- Ethical and legal aspects of autonomous driving.
- Future trends and challenges in urban autonomous vehicle research and development.
6. Urban Autonomous Vehicle Engineering: Robotics, Artificial Intelligence and Applications
6. Urban Autonomous Vehicle Engineering: Robotics, Artificial Intelligence, and Applications
- Development of autonomous navigation systems using advanced sensors such as lidar, radar, and cameras.
- Implementation of perception and environmental recognition algorithms based on computer vision and artificial intelligence.
- Design and programming of motion controllers and trajectory planning for autonomous vehicles.
- Application of machine learning and deep learning techniques for decision-making in complex urban environments.
- Integration of hardware and software on robotic platforms for prototype construction and testing.
- Analysis of the safety and reliability of autonomous systems, including simulation and validation testing in real-world scenarios.
- Exploration of regulations and ethical aspects related to the implementation of autonomous vehicles in urban environments.
- Study of the software and hardware architectures used in the automotive industry.
Autonomous vehicles, including embedded systems and communications.
Research into current and future trends in the field of urban autonomous vehicles, including their impact on mobility and transportation.
Application of simulation and modeling tools for the design and optimization of autonomous vehicle systems.
Who this program is for:
Autonomous Vehicles in Urban Environments Course
- Engineers with degrees in Aerospace Engineering, Mechanical Engineering, Industrial Engineering, Automation Engineering, Electronics Engineering, or related fields.
- Professionals in the automotive and technology industries interested in autonomous vehicles, including software, hardware, and systems engineers.
- Specialists in areas such as artificial intelligence, machine learning, computer vision, and robotics who wish to apply their knowledge in the context of autonomous vehicles.
- Researchers and developers from technology centers, universities, and companies R&D focused on autonomous driving technologies.
Professionals from transportation, logistics, and urban mobility companies seeking to understand and apply autonomous vehicle technologies in their operations.
Public policymakers and regulators who need to acquire knowledge about the impact and regulation of autonomous vehicles.
Recommended requirements: Basic knowledge of programming, calculus, physics, and linear algebra. Previous experience in projects related to autonomous vehicles or related areas will be valued. Language: An upper-intermediate level of English (B2/C1) is required for understanding materials and participating in the course.
- Standards-driven curriculum: you will work with CS-27/CS-29, DO-160, DO-178C/DO-254, ARP4754A/ARP4761, ADS-33E-PRF from the first module.
- Accreditable laboratories (EN ISO/IEC 17025) with rotor bench, EMC/Lightning pre-compliance, HIL/SIL, vibrations/acoustics.
- Evidence-oriented TFM: safety case, test plan, compliance dossierand operational limits.
- Mentored by industry: teachers with experience in rotorcraft, tiltrotor, eVTOL/UAM and flight test.
- Flexible modality (hybrid/online), international cohorts and support from SEIUM Career Services.
- Ethics and security: safety-by-design approach, cyber-OT, DIH and compliance as pillars.
2.1 Advanced Control: Modeling, Design, and Simulation
2.2 Control Architecture: Sensors, Actuators, and Buses
2.3 Fuzzy Logic and Model-Based Predictive Control
2.4 Optimization Methods and Game Theory
2.5 Software-in-the-Loop (SIL) and Hardware-in-the-Loop (HIL)
2.6 Validation and Verification: Norms and Standards
2.7 Simulation Testing: Scenarios and Use Cases
2.8 Failure Modes and Effects Analysis (FMEA)
2.9 Cybersecurity and Data Protection
2.10 Reporting and Documentation: Results and Conclusions
3.2 LiDAR Sensors: Principles, Operation, and Applications
3.2 Computer Vision: Cameras, Image Processing, and Stereo Vision
3.3 Radar Sensors: Types, Characteristics, and Their Use in Autonomous Vehicles
3.4 Sensor Fusion: Techniques and Algorithms for Data Integration
3.5 Machine Learning: Introduction, Models, and Applications in Perception
3.6 Convolutional Neural Networks (CNNs): Architectures and Training for Vision
3.7 Object Detection and Classification: Advanced Techniques and Practical Examples
3.8 Simultaneous Localization and Mapping (SLAM): Algorithms and Implementations
3.9 Pose Estimation: Kalman Filter and Other Techniques
3.20 Case Studies: Applications of Sensors and Algorithms in Autonomous Vehicles
3.3 Fundamentals of Sensors: Types and Principles
3.2 Signal Processing: Filtering and Preprocessing
3.3 Sensor Fusion Algorithms: Kalman, Filters, and More
3.4 Computer Vision: Object Detection and Recognition
3.5 Simultaneous Localization and Mapping (SLAM)
3.6 Hardware Architectures: CPU, GPU, and Other Accelerators
3.7 Real-Time Operating Systems (RTOS)
3.8 Communication and Protocols: CAN, Ethernet
3.9 Artificial Intelligence in Autonomous Vehicles
3.30 Embedded Systems Design for Automotive
4.4 Advanced Sensors for Perception: LiDAR, Radar, Cameras
4.2 Sensor Fusion: Techniques and Algorithms
4.3 Environmental Representation: 2D/3D Maps, SLAM
4.4 Path Planning: Search and Optimization Algorithms
4.5 Autonomous Vehicle Control: PID, Predictive Control
4.6 Control Architectures: Centralized, Distributed
4.7 Decision Making: Fuzzy Logic, Neural Networks
4.8 Safety and Redundancy Systems
4.9 Simulation and Testing in Virtual Environments
4.40 Integration and Validation of Autonomous Systems
5.5 Simulation of complex systems: Modeling and testing
5.5 High-performance simulation environments
5.3 Simulation platforms: ROS, Gazebo, and V-REP
5.4 Performance metrics: KPIs and results evaluation
5.5 Real-world validation: Road tests and challenges
5.6 Failure analysis and troubleshooting
5.7 Debugging and optimization tools
5.8 Platform deployment: Software and hardware development
5.9 Functional safety and cybersecurity
5.50 Ethics and regulation in the deployment of autonomous vehicles
6.6 Fundamentals of Robotics and Autonomous Systems
6.2 Hardware and Software Architecture for Autonomous Vehicles
6.3 Sensors and Environmental Perception
6.4 Artificial Intelligence and Machine Learning for Autonomous Driving
6.5 Path Planning and Motion Control
6.6 Safety System Design and Validation
6.7 Data Integration and Management in Autonomous Vehicles
6.8 Practical Applications and Case Studies
6.9 Simulation and Testing in Virtual Environments
6.60 Ethical and Regulatory Considerations
- Hands-on methodology: test-before-you-trust, design reviews, failure analysis, compliance evidence.
- Software (depending on licenses/partners): MATLAB/Simulink, Python (NumPy/SciPy), OpenVSP, SU2/OpenFOAM, Nastran/Abaqus, AMESim/Modelica, acoustics tools, planning toolchains DO-178C.
- SEIUM Laboratories: scale rotor bench, vibrations/acoustics, EMC/Lightning pre-compliance, HIL/SIL for AFCS, data acquisition with strain gauging.
- Standards and compliance: EN 9100, 17025, ISO 27001, GDPR.
Capstone-type projects
- Autonomous Navigation System: Integration of sensors, route planning algorithms, and vehicle control.
- Simulation and Validation: Development of simulation and testing environments to validate vehicle behavior.
- Perception and Planning: Implementation of perception and route planning systems for complex urban environments.
- Advanced Perception: Implementation of object detection models (car, pedestrian, traffic light) using Deep Learning.
- Path Planning: A* and RRT* algorithms for navigation in complex urban environments.
- Predictive Control: Design of an MPC controller for precise path tracking.
- Simulation and Validation: Complete system simulation in ROS with validation in virtual environments.
- Vehicle Simulation: 3D modeling, virtual environments, collision testing.
- Perception System: Sensor fusion, object detection, classification.
- Path Planning: Navigation algorithms, obstacle avoidance.
- Vehicle Control: Predictive control design, dynamic response.
- Advanced Perception System: Sensor implementation, data fusion, and obstacle detection.
- Intelligent Path Planning: Navigation algorithms, collision avoidance, and route optimization.
- Robust Predictive Control: Controller design, simulation, and validation in complex environments.
Admissions, fees, and scholarships
- Profile: Background in Computer Engineering, Mathematics, Statistics, or related fields; practical experience in NLP and valued information retrieval systems.
- Documentation: Updated CV, academic transcript, SOP/statement of purpose, project examples or code (optional).
- Process: Application → Technical evaluation of profile and experience → Technical interview → Review of case studies → Final decision → Enrollment.
- Fees:
- Single payment: 10% discount.
- Payment in 3 installments: No fees; 30% upon registration + 2 equal monthly payments of the remaining 35%.
Monthly payment: available with a 7% commission on the total; annual review.
Scholarships: based on academic merit, financial need, and promoting inclusion; agreements with companies in the sector for partial or full scholarships.
See “Calendar & Calls for Applications,” “Scholarships & Grants,” and “Fees & Financing” in the SEIUM mega-menu.
Do you have any questions?
Our team is ready to help you. Contact us, and we will respond as soon as possible.
F. A. Q
Frequently asked questions
Yes, we have international certification
Yes: experimental models, real data, applied simulations, professional environments, real case studies.
It is not mandatory. We offer leveling tracks and tutoring.
Completely. It covers e-propulsion, integration, and emerging regulations (SC-VTOL).
Recommended. There are also internal challenges and consortiums.
Yes. Online/hybrid modality with planned labs and visa support (see “Visa & Residence”).